|
AGX Dynamics 2.42.3.1
|
|
AGX Dynamics 2.42.3.1
|
A cylinder shape for geometric intersection tests. More...
#include <Cylinder.h>
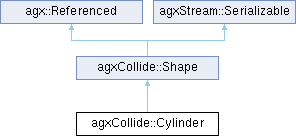
 Inheritance diagram for agxCollide::Cylinder:
Public Member Functions | |
| Cylinder (const agx::Real radius, const agx::Real height) | |
| Constructor. | |
| agx::SPDMatrix3x3 | calculateInertia (agx::Real mass) const override |
| Calculate the inertia of this Cylinder. | |
| virtual BoundingAABB | calculateLocalBound () const override |
| Calculate the bounding volume in the local coordinate system. | |
| virtual Shape * | clone () const override |
| Create a clone. | |
| agx::Real | getHeight () const |
| agx::Real | getRadius () const |
| virtual agx::Vec3 | getSupportPoint (const agx::Vec3 &supportDirection) const override |
| Returns the support point on face of the shape. | |
| virtual agx::Real | getVolume () const override |
| Calculate the volume of this cylinder. | |
| virtual bool | hasSupportFunction () const override |
| void | set (const agx::Real radius, const agx::Real height) |
| Set the radius and height of a cylinder. | |
| void | setHeight (const agx::Real height) |
| Set the height of a cylinder. | |
| void | setRadius (const agx::Real radius) |
| Set the radius of a cylinder. | |
| virtual const BoundingAABB & | updateBoundingVolume () override |
| Calculate the bounding volume based on the current Shape parameters including transformation. | |
| Public Member Functions inherited from agxCollide::Shape | |
| ShapeGroup * | asGroup () |
| Auto-cast shape to group. | |
| const ShapeGroup * | asGroup () const |
| Auto-cast shape to group. | |
| virtual agx::Real | calculateBoundingRadius (BoundingAABB &localAABB) const |
Calculate the bounding volume (AABB) into localAABB and calculate the bounding radius based on the new AABB size. | |
| virtual agx::SPDMatrix3x3 | calculateInertia (agx::Real mass) const =0 |
| Calculate the inertia for the shape given a mass. | |
| virtual BoundingAABB | calculateLocalBound () const =0 |
| Calculate the bounding volume in the local coordinate system. | |
| virtual Shape * | clone () const |
| Create a clone. | |
| const BoundingAABB & | getBoundingVolume () const |
| virtual agx::Vec3 | getCenter () const |
| agx::Physics::Geometry::ShapePtr | getEntity () const |
| Geometry * | getGeometry () |
| const Geometry * | getGeometry () const |
| agx::AffineMatrix4x4 | getLocalTransform () const |
| agx::UInt32 | getModifiedCount () const |
| agxCollide::RenderData * | getRenderData () |
| If this is a ShapeGroup, then this method will return nullptr as the render data is stored in the actual children (Box, Mesh etc. | |
| const agxCollide::RenderData * | getRenderData () const |
| If this is a ShapeGroup, then this method will return nullptr as the render data is stored in the actual children (Box, Mesh etc. | |
| virtual agx::Vec3 | getSupportPoint (const agx::Vec3 &supportDirection) const |
| Returns the support point on face of the shape. | |
| agx::AffineMatrix4x4 | getTransform () const |
| agx::UInt8 | getType () const |
| const char * | getTypeName () const |
| virtual agx::Real | getVolume () const =0 |
| Return the volume of the shape. | |
| virtual bool | hasSupportFunction () const |
| bool | isGroup () const |
| virtual void | propagateTransform (const agx::AffineMatrix4x4 &transform) |
| virtual void | setRenderData (agxCollide::RenderData *renderData) |
| Store render data with the Shape. | |
| virtual const BoundingAABB & | updateBoundingVolume ()=0 |
| Calculate the bounding volume based on the current Shape parameters including transformation. | |
| Public Member Functions inherited from agx::Referenced | |
| Referenced () | |
| Default constructor. | |
| Referenced (const Referenced &) | |
| template<typename T > | |
| T * | as () |
| Subclass casting. | |
| template<typename T > | |
| const T * | as () const |
| template<typename T > | |
| T * | asSafe () |
| Safe subclass casting, return nullptr if template type does not match. | |
| template<typename T > | |
| const T * | asSafe () const |
| int | getReferenceCount () const |
| template<typename T > | |
| bool | is () const |
| Subclass test. | |
| Referenced & | operator= (const Referenced &) |
| Assignment operator. Will increment the number of references to the referenced object. | |
| void | reference (void *ptr=nullptr) const |
| Explicitly increment the reference count by one, indicating that this object has another pointer which is referencing it. | |
| void | unreference (void *ptr=nullptr) const |
| Decrement the reference count by one, indicating that a pointer to this object is referencing it. | |
| void | unreference_nodelete () const |
| Decrement the reference count by one, indicating that a pointer to this object is referencing it. | |
| Public Member Functions inherited from agxStream::Serializable | |
| virtual | ~Serializable () |
| Destructor for normal C++ use but hidden from SWIG bindings. | |
| virtual const char * | getClassName () const |
| bool | getEnableSerialization () const |
| bool | getEnableUuidGeneration () |
| agx::UInt32 | getIndex () const |
| This index is given at creation of this object. | |
| virtual StorageAgent * | getStorageAgent () const =0 |
| agx::Uuid | getUuid () const |
| bool | isFinished () const |
| void | setEnableSerialization (bool flag) |
| Set to false to disable serialization of this object. | |
| void | setFinished () |
| Tells this class that it is restored correctly and should not be deleted during destruction of an Archive. | |
| void | setUuid (const agx::Uuid &uuid) |
| Explicitly set a Uuid on a serializable object. | |
Static Public Member Functions | |
| static BoundingAABB | calculateBound (const agx::AffineMatrix4x4 &transform, const agx::Real radius, const agx::Real height) |
| Static Public Member Functions inherited from agxCollide::Shape | |
| static BoundingAABB | calculateBound (const agx::AffineMatrix4x4 &transform, const BoundingAABB &localBound) |
| static const char * | getTypeName (agx::UInt8 type) |
| Static Public Member Functions inherited from agx::Referenced | |
| template<typename T > | |
| static bool | ValidateCast (const Referenced *object) |
| Static Public Member Functions inherited from agxStream::Serializable | |
| static void | setEnableUuidGeneration (bool flag) |
| Specify if there should be UUID:s generated for each new Serializable object. By default it is enabled. | |
Protected Member Functions | |
| Cylinder () | |
| Hidden default constructor. | |
| Cylinder (agx::Real radius, agx::Real height, agxCollide::Shape::Type type, agx::Physics::Geometry::ShapePtr entity) | |
| Internal constructor. | |
| virtual | ~Cylinder () |
| Destructor. | |
| Protected Member Functions inherited from agxCollide::Shape | |
| Shape (Type type, agx::Physics::Geometry::ShapePtr entity=agx::Physics::Geometry::ShapeModel::createInstance()) | |
| Constructor. | |
| virtual | ~Shape () |
| Destructor. | |
| agx::UInt32 | incrementModifiedCount () |
| Increment the number of times the shape have been modified. | |
| void | syncronizeShapeIndex () |
| Protected Member Functions inherited from agx::Referenced | |
| virtual | ~Referenced () |
| Destructor. | |
| void | allocateObserverVector () const |
| void | deleteUsingDeleteHandler () const |
| Protected Member Functions inherited from agxStream::Serializable | |
| Serializable () | |
| Default constructor. | |
| Serializable (const Serializable &other) | |
| Copy constructor. | |
| void | generateUuid () |
Additional Inherited Members | |
| Public Types inherited from agxCollide::Shape | |
| enum | Type { GROUP , BOX , CAPSULE , CYLINDER , LINE , PLANE , SPHERE , TRIMESH , HEIGHT_FIELD , CONVEX , WIRE_SHAPE , CONE , HOLLOW_CONE , HOLLOW_CYLINDER , TIRE_SHAPE , NUM_TYPES } |
| Define the type of a Shape. More... | |
| Static Protected Member Functions inherited from agx::Referenced | |
| static DeleteHandler * | getDeleteHandler () |
| static void | setDeleteHandler (DeleteHandler *handler) |
| Internal: Set a DeleteHandler to which deletion of all referenced counted objects will be delegated to. | |
| Protected Attributes inherited from agxCollide::Shape | |
| agx::Physics::Geometry::ShapeRef | m_entity |
| Geometry * | m_geometry |
| agx::ref_ptr< agx::Referenced > | m_internalData |
| ShapeGroup * | m_parent |
| agxCollide::RenderDataRef | m_renderData |
| agx::Index | m_shapeIndex |
| Protected Attributes inherited from agx::Referenced | |
| Mutex | m_mutex |
| ObserverContainer | m_observers |
| AtomicValue | m_refCount |
A cylinder shape for geometric intersection tests.
Definition a cylinder is oriented along the Y-axis with origin at center of mass.
Definition at line 34 of file Cylinder.h.
Constructor.
| radius | Radius of cylinder |
| height | Height of cylinder |
|
protected |
Hidden default constructor.
|
protected |
Internal constructor.
|
protectedvirtual |
Destructor.
|
static |
Definition at line 127 of file Cylinder.h.
|
overridevirtual |
Calculate the inertia of this Cylinder.
Implements agxCollide::Shape.
|
overridevirtual |
Calculate the bounding volume in the local coordinate system.
Implements agxCollide::Shape.
|
overridevirtual |
Create a clone.
Reimplemented from agxCollide::Shape.
| agx::Real agxCollide::Cylinder::getHeight | ( | ) | const |
Definition at line 114 of file Cylinder.h.
| agx::Real agxCollide::Cylinder::getRadius | ( | ) | const |
Definition at line 118 of file Cylinder.h.
|
overridevirtual |
Returns the support point on face of the shape.
| supportDirection | - Direction in shape coords where to find a support point |
Reimplemented from agxCollide::Shape.
|
overridevirtual |
Calculate the volume of this cylinder.
Implements agxCollide::Shape.
Definition at line 122 of file Cylinder.h.
References agx::PI.
|
inlineoverridevirtual |
Reimplemented from agxCollide::Shape.
Definition at line 132 of file Cylinder.h.
Set the radius and height of a cylinder.
| height | - New height of the cylinder |
| radius | - New radius of the cylinder |
| void agxCollide::Cylinder::setHeight | ( | const agx::Real | height | ) |
Set the height of a cylinder.
| height | - New height of the cylinder |
| void agxCollide::Cylinder::setRadius | ( | const agx::Real | radius | ) |
Set the radius of a cylinder.
| radius | - New radius of the cylinder |
|
overridevirtual |
Calculate the bounding volume based on the current Shape parameters including transformation.
Implements agxCollide::Shape.
 1.9.6