|
AGX Dynamics 2.42.3.0
|
|
AGX Dynamics 2.42.3.0
|
A contact between two geometries. More...
#include <Contacts.h>
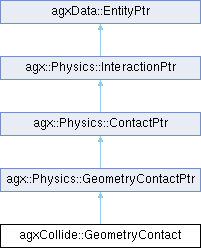
 Inheritance diagram for agxCollide::GeometryContact:
Public Types | |
| enum | ContactState { NO_CONTACT = 0 , IMPACT_STATE = 1 , CONTACT_STATE = 2 , SEPARATION_STATE = 3 } |
| Specify the state of the contact. More... | |
| typedef ContactPoint | PointType |
| Public Types inherited from agx::Physics::GeometryContactPtr | |
| typedef GeometryContactData | DataType |
| typedef GeometryContactInstance | InstanceType |
| typedef GeometryContactModel | ModelType |
| Public Types inherited from agx::Physics::ContactPtr | |
| typedef ContactData | DataType |
| typedef ContactInstance | InstanceType |
| typedef ContactModel | ModelType |
| Public Types inherited from agx::Physics::InteractionPtr | |
| typedef InteractionData | DataType |
| typedef InteractionInstance | InstanceType |
| typedef InteractionModel | ModelType |
Public Member Functions | |
| GeometryContact () | |
| Default constructor. | |
| GeometryContact (agx::Physics::GeometryContactPtr contact) | |
| Construct given geometry contact entity data. | |
| agx::Vec3f | calculateRelativeVelocity (size_t pointIndex=0) const |
| Calculate the relative velocity in a contact point. | |
| void | clear () |
| Clear contact points. | |
| int | contains (agx::RigidBody *body) const |
| Will return -1 if body does not exist in this GeometryContact, 0 if it is the first (index 0) and 1 if it is the second (index 1). | |
| int | contains (agxCollide::Geometry *geometry) const |
| Will return -1 if geometry does not exist in this GeometryContact, 0 if it is the first (index 0) and 1 if it is the second (index 1). | |
| agxCollide::Geometry * | geometry (size_t ith) |
| const agxCollide::Geometry * | geometry (size_t ith) const |
| void * | getCustomData () |
| const void * | getCustomData () const |
| agx::ContactMaterial * | getMaterial () |
| If the contact material for this geometry contact is explicit it can be accessed here. | |
| const agx::ContactMaterial * | getMaterial () const |
| If the contact material for this geometry contact is explicit it can be accessed here. | |
| const agx::ContactMaterial * | getMaterial (bool) const |
| It's not possible to change parameters in an implicit contact material. | |
| agx::Bool | hasImpactingPoints () const |
| bool | isEnabled () const |
| ContactPointVector & | points () |
| const ContactPointVector & | points () const |
| void | removeContactPoint (ContactPoint &point) |
| remove the specified ContactPoint from the set of contact points. | |
| agx::RigidBody * | rigidBody (size_t ith) |
| Returns access to rigid body data. | |
| const agx::RigidBody * | rigidBody (size_t ith) const |
| Returns access to rigid body data. | |
| void | setCustomData (void *customData) |
| Store custom data for this Contact. | |
| void | setEnable (bool flag) |
| Set to false to disable the contact. | |
| agx::UInt8 | state () const |
| Public Member Functions inherited from agx::Physics::GeometryContactPtr | |
| AGXPHYSICS_EXPORT | GeometryContactPtr () |
| AGXPHYSICS_EXPORT | GeometryContactPtr (agxData::EntityStorage *storage, agx::Index id) |
| AGXPHYSICS_EXPORT | GeometryContactPtr (const agxData::EntityInstance &instance) |
| AGXPHYSICS_EXPORT | GeometryContactPtr (const agxData::EntityPtr &ptr) |
| AGXPHYSICS_EXPORT agx::Physics::RigidBodyPtr & | body1 () |
| body1 is the rigid body of geometry1, can be assumed to be a valid rigid body. | |
| AGXPHYSICS_EXPORT agx::Physics::RigidBodyPtr const & | body1 () const |
| body1 is the rigid body of geometry1, can be assumed to be a valid rigid body. | |
| AGXPHYSICS_EXPORT agx::Physics::RigidBodyPtr & | body2 () |
| body2 is the rigid body of geometry2, can be NULL. | |
| AGXPHYSICS_EXPORT agx::Physics::RigidBodyPtr const & | body2 () const |
| body2 is the rigid body of geometry2, can be NULL. | |
| AGXPHYSICS_EXPORT agx::Physics::BroadPhasePairPtr & | broadPhasePair () |
| AGXPHYSICS_EXPORT agx::Physics::BroadPhasePairPtr const & | broadPhasePair () const |
| AGXPHYSICS_EXPORT void *& | customData () |
| AGXPHYSICS_EXPORT void *const & | customData () const |
| AGXPHYSICS_EXPORT agx::Bool & | enabled () |
| AGXPHYSICS_EXPORT agx::Bool const & | enabled () const |
| AGXPHYSICS_EXPORT agx::Physics::GeometryPtr & | geometry1 () |
| AGXPHYSICS_EXPORT agx::Physics::GeometryPtr const & | geometry1 () const |
| AGXPHYSICS_EXPORT agx::Physics::GeometryPtr & | geometry2 () |
| AGXPHYSICS_EXPORT agx::Physics::GeometryPtr const & | geometry2 () const |
| GeometryContactData * | getData () |
| const GeometryContactData * | getData () const |
| AGXPHYSICS_EXPORT agx::Bool & | hasInternalMaterial () |
| AGXPHYSICS_EXPORT agx::Bool const & | hasInternalMaterial () const |
| AGXPHYSICS_EXPORT agx::Bool & | hasSurfaceVelocity () |
| AGXPHYSICS_EXPORT agx::Bool const & | hasSurfaceVelocity () const |
| AGXPHYSICS_EXPORT agx::Bool & | immediately () |
| AGXPHYSICS_EXPORT agx::Bool const & | immediately () const |
| AGXPHYSICS_EXPORT GeometryContactInstance | instance () |
| AGXPHYSICS_EXPORT const GeometryContactInstance | instance () const |
| AGXPHYSICS_EXPORT GeometryContactSemantics * | operator-> () |
| AGXPHYSICS_EXPORT const GeometryContactSemantics * | operator-> () const |
| AGXPHYSICS_EXPORT GeometryContactPtr & | operator= (const agxData::EntityInstance &instance) |
| AGXPHYSICS_EXPORT GeometryContactPtr & | operator= (const agxData::EntityPtr &ptr) |
| AGXPHYSICS_EXPORT agxData::Array< agx::Physics::ContactPointPtr > & | points () |
| The list of contact points. | |
| AGXPHYSICS_EXPORT agxData::Array< agx::Physics::ContactPointPtr > const & | points () const |
| The list of contact points. | |
| AGXPHYSICS_EXPORT agx::Bool & | usingPPGS () |
| AGXPHYSICS_EXPORT agx::Bool const & | usingPPGS () const |
| Public Member Functions inherited from agx::Physics::ContactPtr | |
| AGXPHYSICS_EXPORT | ContactPtr () |
| AGXPHYSICS_EXPORT | ContactPtr (agxData::EntityStorage *storage, agx::Index id) |
| AGXPHYSICS_EXPORT | ContactPtr (const agxData::EntityInstance &instance) |
| AGXPHYSICS_EXPORT | ContactPtr (const agxData::EntityPtr &ptr) |
| AGXPHYSICS_EXPORT agx::UInt32 & | constraintIndex () |
| AGXPHYSICS_EXPORT agx::UInt32 const & | constraintIndex () const |
| AGXPHYSICS_EXPORT agx::UInt32 & | contactZoneIndex () |
| AGXPHYSICS_EXPORT agx::UInt32 const & | contactZoneIndex () const |
| AGXPHYSICS_EXPORT agx::UInt16 & | contactZoneSlot () |
| AGXPHYSICS_EXPORT agx::UInt16 const & | contactZoneSlot () const |
| ContactData * | getData () |
| const ContactData * | getData () const |
| AGXPHYSICS_EXPORT ContactInstance | instance () |
| AGXPHYSICS_EXPORT const ContactInstance | instance () const |
| AGXPHYSICS_EXPORT agx::Physics::ContactMaterialPtr & | material () |
| AGXPHYSICS_EXPORT agx::Physics::ContactMaterialPtr const & | material () const |
| AGXPHYSICS_EXPORT ContactSemantics * | operator-> () |
| AGXPHYSICS_EXPORT const ContactSemantics * | operator-> () const |
| AGXPHYSICS_EXPORT ContactPtr & | operator= (const agxData::EntityInstance &instance) |
| AGXPHYSICS_EXPORT ContactPtr & | operator= (const agxData::EntityPtr &ptr) |
| Public Member Functions inherited from agx::Physics::InteractionPtr | |
| AGXPHYSICS_EXPORT | InteractionPtr () |
| AGXPHYSICS_EXPORT | InteractionPtr (agxData::EntityStorage *storage, agx::Index id) |
| AGXPHYSICS_EXPORT | InteractionPtr (const agxData::EntityInstance &instance) |
| AGXPHYSICS_EXPORT | InteractionPtr (const agxData::EntityPtr &ptr) |
| InteractionData * | getData () |
| const InteractionData * | getData () const |
| AGXPHYSICS_EXPORT agx::Physics::GraphNodePtr & | graphNode () |
| AGXPHYSICS_EXPORT agx::Physics::GraphNodePtr const & | graphNode () const |
| AGXPHYSICS_EXPORT InteractionInstance | instance () |
| AGXPHYSICS_EXPORT const InteractionInstance | instance () const |
| AGXPHYSICS_EXPORT InteractionSemantics * | operator-> () |
| AGXPHYSICS_EXPORT const InteractionSemantics * | operator-> () const |
| AGXPHYSICS_EXPORT InteractionPtr & | operator= (const agxData::EntityInstance &instance) |
| AGXPHYSICS_EXPORT InteractionPtr & | operator= (const agxData::EntityPtr &ptr) |
| AGXPHYSICS_EXPORT agx::SolveModel *& | solveModel () |
| AGXPHYSICS_EXPORT agx::SolveModel *const & | solveModel () const |
| Public Member Functions inherited from agxData::EntityPtr | |
| EntityPtr () | |
| EntityPtr (agxData::EntityStorage *storage, agx::Index id) | |
| EntityPtr (const agxData::EntityInstance &instance) | |
| EntityPtr (const agxData::EntityPtr &other)=default | |
| ~EntityPtr ()=default | |
| agx::Index | calculateIndex () const |
| Calculate the index using the indirect id. | |
| agxData::EntityPtr | copy () |
| Create a copy instance in the same storage. | |
| agxData::EntityPtr | copy (agxData::EntityStorage *target) |
| Copy instance to another storage. | |
| void | copyAttributes (agxData::EntityPtr source) |
| Copy instance attributes to an existing target instance. | |
| template<typename T > | |
| T & | dataSet () |
| template<typename T > | |
| const T & | dataSet () const |
| void | destroy () |
| Remove the entity from the active storage. | |
| agxData::EntityData * | getData () |
| const agxData::EntityData * | getData () const |
| agx::Index | getId () const |
| agxData::EntityModel * | getModel () |
| const agxData::EntityModel * | getModel () const |
| agxData::EntityStorage * | getStorage () const |
| agx::UInt32 | hash () const |
| void | init (agxData::EntityStorage *storage, agx::Index id) |
| Set the target storage and id. | |
| agxData::EntityInstance | instance () |
| const agxData::EntityInstance | instance () const |
| void | invalidate () |
| Invalidate the entity pointer. | |
| bool | isInstanceOf (agxData::EntityModel *model) const |
| bool | isValid () const |
| operator bool () const | |
| bool | operator! () const |
| bool | operator!= (const EntityPtr &rhs) const |
| template<typename T > | |
| agxData::ArrayAttributeT< T >::Type & | operator() (const agxData::ArrayAttributeT< T > *attribute) |
| Array attribute. | |
| template<typename T > | |
| const agxData::ArrayAttributeT< T >::Type & | operator() (const agxData::ArrayAttributeT< T > *attribute) const |
| template<typename T > | |
| agxData::HashSetAttributeT< T >::Type & | operator() (const agxData::HashSetAttributeT< T > *attribute) |
| HashSet attribute. | |
| template<typename T > | |
| const agxData::HashSetAttributeT< T >::Type & | operator() (const agxData::HashSetAttributeT< T > *attribute) const |
| template<typename T > | |
| T & | operator() (const agxData::PointerAttributeT< T > *attribute) |
| Pointer attribute. | |
| template<typename T > | |
| const T & | operator() (const agxData::PointerAttributeT< T > *attribute) const |
| template<typename T > | |
| T & | operator() (const agxData::ScalarAttributeT< T > *attribute) |
| Access the value of a specific attribute. | |
| template<typename T > | |
| const T & | operator() (const agxData::ScalarAttributeT< T > *attribute) const |
| template<typename T > | |
| T & | operator() (const agxData::SharedAttributeT< T > *attribute) |
| Shared attribute. | |
| template<typename T > | |
| const T & | operator() (const agxData::SharedAttributeT< T > *attribute) const |
| template<typename T > | |
| agxData::VectorAttributeT< T >::Type & | operator() (const agxData::VectorAttributeT< T > *attribute) |
| Vector attribute. | |
| template<typename T > | |
| const agxData::VectorAttributeT< T >::Type & | operator() (const agxData::VectorAttributeT< T > *attribute) const |
| template<typename T > | |
| ArrayAttributeT< T >::Type & | operator() (const ArrayAttributeT< T > *attribute) |
| template<typename T > | |
| const ArrayAttributeT< T >::Type & | operator() (const ArrayAttributeT< T > *attribute) const |
| template<typename T > | |
| HashSetAttributeT< T >::Type & | operator() (const HashSetAttributeT< T > *attribute) |
| template<typename T > | |
| const HashSetAttributeT< T >::Type & | operator() (const HashSetAttributeT< T > *attribute) const |
| template<typename T > | |
| VectorAttributeT< T >::Type & | operator() (const VectorAttributeT< T > *attribute) |
| template<typename T > | |
| const VectorAttributeT< T >::Type & | operator() (const VectorAttributeT< T > *attribute) const |
| bool | operator< (const EntityPtr &rhs) const |
| EntityPtr & | operator= (const EntityPtr &other)=default |
| EntityPtr & | operator= (EntityPtr &&)=default |
| bool | operator== (const EntityPtr &rhs) const |
| bool | operator> (const EntityPtr &rhs) const |
| void | print () const |
| void | print (std::ostream &stream) const |
| void | swapId (EntityPtr &other) |
| Swap id with another instance. | |
| void | swapIndex (EntityPtr &other) |
| Swap index with another instance. | |
| void | transfer (agxData::EntityStorage *target) |
| Transfer instance to another storage. | |
| void | verifyIndex () const |
| Check for broken ptr, by verifying that the id is active in the storage. | |
Static Public Member Functions | |
| static bool | calculateSurfaceVelocity (const agxCollide::Geometry *geometry1, const agxCollide::Geometry *geometry2, ContactPoint &p) |
Calculate the relative velocity in a contact point between geometry1 and geometry2 Put result in p. | |
| static bool | calculateSurfaceVelocity (const agxCollide::Geometry *geometry1, const agxCollide::Geometry *geometry2, LocalContactPoint &p) |
Calculate the relative velocity in a contact point between geometry1 and geometry2 Put result in p. | |
| Static Public Member Functions inherited from agxData::EntityPtr | |
| static EntityPtr | createWithIndex (EntityStorage *storage, agx::Index index) |
| static void | TransformToAscii (void *targetBuffer, const void *sourceBuffer, size_t numElements) |
A contact between two geometries.
Definition at line 353 of file Contacts.h.
Definition at line 356 of file Contacts.h.
Specify the state of the contact.
| Enumerator | |
|---|---|
| NO_CONTACT | ! No contact yet |
| IMPACT_STATE | ! First contact |
| CONTACT_STATE | ! Continuous contact |
| SEPARATION_STATE | ! Contact in last time step, now separated |
Definition at line 360 of file Contacts.h.
| agxCollide::GeometryContact::GeometryContact | ( | ) |
Default constructor.
Definition at line 710 of file Contacts.h.
| agxCollide::GeometryContact::GeometryContact | ( | agx::Physics::GeometryContactPtr | contact | ) |
Construct given geometry contact entity data.
| contact | - other geometry (to copy from) |
Definition at line 715 of file Contacts.h.
| agx::Vec3f agxCollide::GeometryContact::calculateRelativeVelocity | ( | size_t | pointIndex = 0 | ) | const |
Calculate the relative velocity in a contact point.
| pointIndex | - The contact point index in the points array containing all contact points for this pair of geometries. |
Definition at line 753 of file Contacts.h.
References agx::RigidBody::getAngularVelocity(), agx::RigidBody::getCmPosition(), agx::RigidBody::getVelocity(), points(), and rigidBody().
|
inlinestatic |
Calculate the relative velocity in a contact point between geometry1 and geometry2 Put result in p.
Definition at line 771 of file Contacts.h.
References calculateSurfaceVelocity(), agx::Physics::GeometryContactPtr::geometry1(), agx::Physics::GeometryContactPtr::geometry2(), agx::Physics::GeometryContactPtr::hasSurfaceVelocity(), agx::Physics::ContactPointPtr::point(), agxCollide::LocalContactPoint::point(), agx::Physics::ContactPointPtr::velocity(), and agxCollide::LocalContactPoint::velocity().
|
static |
Calculate the relative velocity in a contact point between geometry1 and geometry2 Put result in p.
Referenced by calculateSurfaceVelocity().
| void agxCollide::GeometryContact::clear | ( | ) |
Clear contact points.
|
inline |
Will return -1 if body does not exist in this GeometryContact, 0 if it is the first (index 0) and 1 if it is the second (index 1).
This index (if > -1) can be used to get the rigid body with a call to rigidBody(idx)
| body | - the rigid body that you want to look for in this geometry contact |
body does not exist in this GeometryContact, 0 if it is the first and 1 if it is the second Definition at line 565 of file Contacts.h.
|
inline |
Will return -1 if geometry does not exist in this GeometryContact, 0 if it is the first (index 0) and 1 if it is the second (index 1).
This index (if > -1) can be used to get the geometry with a call to geometry(idx)
| geometry | - The geometry that you want to look for in this geometry contact |
geometry does not exist in this GeometryContact, 0 if it is the first and 1 if it is the second Definition at line 572 of file Contacts.h.
References geometry().
| agxCollide::Geometry * agxCollide::GeometryContact::geometry | ( | size_t | ith | ) |
| ith | - index of geometry, 0 or 1. |
Definition at line 721 of file Contacts.h.
References agxAssert, agx::Physics::GeometryContactPtr::geometry1(), agx::Physics::GeometryContactPtr::geometry2(), and agx::Physics::GeometryPtr::model().
Referenced by contains(), and agxSDK::ExecuteFilter::match().
| const agxCollide::Geometry * agxCollide::GeometryContact::geometry | ( | size_t | ith | ) | const |
| ith | - index of geometry, 0 or 1. |
Definition at line 730 of file Contacts.h.
References agxAssert, agx::Physics::GeometryContactPtr::geometry1(), agx::Physics::GeometryContactPtr::geometry2(), and agx::Physics::GeometryPtr::model().
| void * agxCollide::GeometryContact::getCustomData | ( | ) |
Definition at line 808 of file Contacts.h.
References agx::Physics::GeometryContactPtr::customData().
| const void * agxCollide::GeometryContact::getCustomData | ( | ) | const |
Definition at line 813 of file Contacts.h.
References agx::Physics::GeometryContactPtr::customData().
| agx::ContactMaterial * agxCollide::GeometryContact::getMaterial | ( | ) |
If the contact material for this geometry contact is explicit it can be accessed here.
If the contact material in this geometry contact is implicit, this method will return 0, and you have to create an explicit contact material with help of agxSDK::MaterialManager::getOrCreateContactMaterial.
Definition at line 846 of file Contacts.h.
References agx::Physics::ContactPtr::material(), and agx::Physics::ContactMaterialPtr::model().
Referenced by agxSDK::FrictionModelFilter::match().
| const agx::ContactMaterial * agxCollide::GeometryContact::getMaterial | ( | ) | const |
If the contact material for this geometry contact is explicit it can be accessed here.
If the contact material in this geometry contact is implicit, this method will return 0, and you have to create an explicit contact material with help of agxSDK::MaterialManager::getOrCreateContactMaterial.
Definition at line 853 of file Contacts.h.
References agx::Physics::ContactPtr::material(), and agx::Physics::ContactMaterialPtr::model().
| const agx::ContactMaterial * agxCollide::GeometryContact::getMaterial | ( | bool | ) | const |
It's not possible to change parameters in an implicit contact material.
This method returns any type of contact material but const. It's recommended to use the getMaterial() method, this method is used internally.
Definition at line 860 of file Contacts.h.
References agx::Physics::ContactPtr::material(), and agx::Physics::ContactMaterialPtr::model().
| agx::Bool agxCollide::GeometryContact::hasImpactingPoints | ( | ) | const |
| bool agxCollide::GeometryContact::isEnabled | ( | ) | const |
Definition at line 835 of file Contacts.h.
References agx::Physics::GeometryContactPtr::enabled().
| ContactPointVector & agxCollide::GeometryContact::points | ( | ) |
Definition at line 798 of file Contacts.h.
References agx::Physics::GeometryContactPtr::points().
Referenced by calculateRelativeVelocity().
| const ContactPointVector & agxCollide::GeometryContact::points | ( | ) | const |
Definition at line 803 of file Contacts.h.
References agx::Physics::GeometryContactPtr::points().
| void agxCollide::GeometryContact::removeContactPoint | ( | ContactPoint & | point | ) |
remove the specified ContactPoint from the set of contact points.
| agx::RigidBody * agxCollide::GeometryContact::rigidBody | ( | size_t | ith | ) |
Returns access to rigid body data.
| ith | - index of RigidBody, 0 or 1. |
Definition at line 783 of file Contacts.h.
References agxAssert, agx::Physics::GeometryContactPtr::body1(), and agx::Physics::GeometryContactPtr::body2().
Referenced by calculateRelativeVelocity().
| const agx::RigidBody * agxCollide::GeometryContact::rigidBody | ( | size_t | ith | ) | const |
Returns access to rigid body data.
| ith | - index of RigidBody, 0 or 1. |
Definition at line 790 of file Contacts.h.
References agxAssert, agx::Physics::GeometryContactPtr::body1(), and agx::Physics::GeometryContactPtr::body2().
|
inline |
Store custom data for this Contact.
| customData | - data to be stored |
Definition at line 818 of file Contacts.h.
References agx::Physics::GeometryContactPtr::customData().
| void agxCollide::GeometryContact::setEnable | ( | bool | flag | ) |
Set to false to disable the contact.
Definition at line 830 of file Contacts.h.
References agx::Physics::GeometryContactPtr::enabled().
| agx::UInt8 agxCollide::GeometryContact::state | ( | ) | const |
Definition at line 888 of file Contacts.h.
References agx::Physics::GeometryContactPtr::broadPhasePair(), NO_CONTACT, and agx::Physics::BroadPhasePairPtr::state().
 1.9.6