|
| | DryClutch () |
| |
| agx::Real | getDisengageTimeConstant () const |
| |
| agx::Real | getEngageTimeConstant () const |
| |
| agx::Real | getFraction () const |
| |
| agx::Real | getInputVelocity () const |
| |
| agx::Real | getMinRelativeSlip () const |
| |
| agx::Real | getOutputVelocity () const |
| |
| agx::Real | getSlip () const |
| |
| agx::Real | getTorque () const |
| |
| agx::Real | getTorqueCapacity () const |
| |
| bool | isAutoLock () const |
| |
| bool | isEngaged () const |
| |
| bool | isLocked () const |
| | Returns the lock status.
|
| |
| bool | isManualMode () const |
| |
| void | setAutoLock (bool autoLock) |
| | In auto lock mode, the friction plates will lock when the slip is small enough in proportion to the velocity of the input shaft.
|
| |
| void | setDisengageTimeConstant (agx::Real tau) |
| | Set the time constant for clutch disengagement.
|
| |
| void | setEngage (bool engage) |
| | Puts the clutch pedal in assisted mode so it will fully engage or disengage in a time period determined by setTimeConstant below.
|
| |
| void | setEngageTimeConstant (agx::Real tau) |
| | Set the time constant for the clutch engagement.
|
| |
| void | setFraction (agx::Real fraction) |
| |
| void | setLock (bool setLock) |
| | Lock or unlock the friction plates.
|
| |
| void | setManualMode (bool manual) |
| | When manual mode is true, user must control all aspects of the clutch engagement and disengagement.
|
| |
| void | setMinRelativeSlip (agx::Real minRelativeSlip) |
| | In autolock mode, the friction plates will lock with the ratio of slip to input shaft velocity is less than this threshold.
|
| |
| void | setTorqueCapacity (agx::Real capacity) |
| | This is the maximum torque that the friction plates can transfer: it will slip if this MinRelativeSlip is exceeded.
|
| |
| | RotationalConnector () |
| | Create a connector between two rotational dimensions.
|
| |
| | AGXSTREAM_DECLARE_SERIALIZABLE_BASE (agxPowerLine::RotationalConnector) |
| |
| virtual agx::RegularizationParameters::VariableType | calculateComplianceAndDamping (const agx::Real timeStep, agx::Real &compliance, agx::Real &damping) override |
| | Calculate a compliance that will result in the wanted efficiency.
|
| |
| virtual PhysicalDimensionMultiBodyConstraintImplementation * | createConstraint () override |
| | Create a gear constraint.
|
| |
| virtual bool | restore (agxStream::StorageStream &str) override |
| | Restores internal data from stream.
|
| |
| virtual bool | store (agxStream::StorageStream &str) const override |
| | Stores internal data into stream.
|
| |
| | Connector () |
| | create a connector
|
| |
| virtual bool | addNotification (agxSDK::Simulation *simulation) override |
| |
| | AGXSTREAM_DECLARE_ABSTRACT_SERIALIZABLE (agxPowerLine::Connector) |
| |
| virtual agx::RegularizationParameters::VariableType | calculateComplianceAndDamping (const agx::Real, agx::Real &, agx::Real &) |
| | Calculate the compliance and damping according to the connector properties (efficiency, ratio, ..)
|
| |
| agx::Real | calculateEfficiency () const |
| | calculate simulated efficiency
|
| |
| virtual agx::Real | calculateViolation () const |
| | calculate violation for constraint
|
| |
| bool | compareWithInputTypes (PhysicalDimensionRefVector &dimensions) const |
| |
| bool | compareWithOutputTypes (PhysicalDimensionRefVector &dimensions) const |
| |
| bool | connect (agxPowerLine::PhysicalDimension *dimension, agxPowerLine::Side connectorSide, agxPowerLine::Side dimensionSide) |
| | Connect on the physical dimension level only.
|
| |
| virtual bool | connect (agxPowerLine::PhysicalDimension *inputDimension, agxPowerLine::Side inputSide, agxPowerLine::Side outputSide, agxPowerLine::PhysicalDimension *outputDimension) |
| |
| virtual bool | connect (agxPowerLine::Side mySide, agxPowerLine::Side unitSide, agxPowerLine::Unit *unit) |
| |
| virtual bool | connect (agxPowerLine::Unit *unit) |
| | Connect a unit to this Connector.
|
| |
| bool | connectDimensions (Unit *unit, agxPowerLine::Side mySide, agxPowerLine::Side unitSide) |
| |
| virtual agxPowerLine::PhysicalDimensionMultiBodyConstraintImplementation * | createConstraint ()=0 |
| | Create the constraint (implement this to create whatever constraint you need)
|
| |
| virtual bool | disconnect () |
| |
| bool | disconnect (agxPowerLine::PhysicalDimension *dimension, agxPowerLine::Side connectorSide, agxPowerLine::Side dimensionSide) |
| |
| virtual bool | disconnect (agxPowerLine::Unit *unit) |
| | Disconnect the given unit from this Connector.
|
| |
| agxPowerLine::Connection * | findConnection (const agxPowerLine::Unit *unit, agxPowerLine::Side side) |
| |
| const agxPowerLine::Connection * | findConnection (const agxPowerLine::Unit *unit, agxPowerLine::Side side) const |
| |
| agxPowerLine::Connection * | findInputConnection (const agxPowerLine::Unit *unit) |
| |
| const agxPowerLine::Connection * | findInputConnection (const agxPowerLine::Unit *unit) const |
| |
| agxPowerLine::Connection * | findOutputConnection (const agxPowerLine::Unit *unit) |
| |
| const agxPowerLine::Connection * | findOutputConnection (const agxPowerLine::Unit *unit) const |
| |
| const agxPowerLine::ConnectionRefVector & | getConnections (agxPowerLine::Side side) const |
| |
| agxPowerLine::PhysicalDimensionMultiBodyConstraintImplementation * | getConstraint () const |
| |
| agx::Real | getDamping () const |
| |
| agxPowerLine::ElementaryPhysicalDimensionConstraint * | getElementaryConstraint () const |
| |
| bool | getIgnoreForStoreRestoreStream () const |
| |
| agxPowerLine::Connection * | getInputConnection (size_t index) |
| | return a specific input connection
|
| |
| const agxPowerLine::Connection * | getInputConnection (size_t index) const |
| | return a specific output connection
|
| |
| agxPowerLine::ConnectionRefVector & | getInputConnections () |
| | return vector to all input connections from this connector
|
| |
| const agxPowerLine::ConnectionRefVector & | getInputConnections () const |
| | return vector to all input connections from this connector
|
| |
| PhysicalDimension * | getInputDimension (const PhysicalDimension::Type dimensionType) const |
| |
| const DimensionTypeVector & | getInputTypes () const |
| |
| bool | getInputUnits (UnitConstPtrSetVector &units, const bool startFromCleanUnitSet=true) const |
| |
| bool | getInputUnits (UnitPtrSetVector &units, const bool startFromCleanUnitSet=true) |
| |
| int | getNumConnections () const |
| |
| int | getNumConnections (agxPowerLine::Side side) const |
| |
| int | getNumFreeConnections () const |
| |
| int | getNumFreeConnections (agxPowerLine::Side side) const |
| |
| int | getNumFreeInputConnections () const |
| |
| int | getNumFreeOutputConnections () const |
| |
| int | getNumInputConnections () const |
| |
| int | getNumOutputConnections () const |
| |
| int | getNumPossibleInputConnections () const |
| |
| int | getNumPossibleOutputConnections () const |
| |
| agxPowerLine::Connection * | getOutputConnection (size_t index) |
| | return a specific input connection
|
| |
| const agxPowerLine::Connection * | getOutputConnection (size_t index) const |
| | return a specific output connection
|
| |
| agxPowerLine::ConnectionRefVector & | getOutputConnections () |
| | return vector to all output connections from this connector
|
| |
| const agxPowerLine::ConnectionRefVector & | getOutputConnections () const |
| | return vector to all output connections from this connector
|
| |
| PhysicalDimension * | getOutputDimension (const PhysicalDimension::Type dimensionType) const |
| |
| const DimensionTypeVector & | getOutputTypes () const |
| |
| bool | getOutputUnits (UnitConstPtrSetVector &units, const bool startFromCleanUnitSet=true) const |
| |
| bool | getOutputUnits (UnitPtrSetVector &units, const bool startFromCleanUnitSet=true) |
| |
| agx::Real | getPowerIn () const |
| |
| agxPowerLine::PowerLine * | getPowerLine () const |
| |
| agx::Real | getPowerOut () const |
| |
| agx::Real | getRatio () const |
| |
| virtual agx::Real | getRatio (agx::Real x) const |
| |
| agx::Real | getRatioDerivative () const |
| |
| virtual agx::Real | getRatioDerivative (agx::Real x) const |
| |
| virtual agxPowerLine::Side | getSide (const agxPowerLine::Unit *unit) const |
| |
| const DimensionTypeVector & | getTypes (agxPowerLine::Side side) const |
| |
| bool | getUnits (UnitConstPtrSetVector &units, agxPowerLine::Side side, const bool startFromCleanUnitSet=true) const |
| |
| bool | getUnits (UnitConstPtrSetVector &units, const bool startFromCleanUnitSet=true) const |
| |
| bool | getUnits (UnitPtrSetVector &units, agxPowerLine::Side side, const bool startFromCleanUnitSet=true) |
| |
| bool | getUnits (UnitPtrSetVector &units, const bool startFromCleanUnitSet=true) |
| |
| virtual agx::Real | getViolation () const |
| | Returns the constraint violation for connectors with holonomic constraints.
|
| |
| bool | hasFreeConnection () const |
| |
| bool | hasFreeConnection (agxPowerLine::Side side) const |
| |
| bool | hasFreeInputConnection () const |
| |
| bool | hasFreeOutputConnection () const |
| |
| bool | hasInputConnection (Connection *connection) |
| | Find out if the connection belongs to this connector.
|
| |
| bool | hasOutputConnection (Connection *connection) |
| |
| virtual void | initConstraint () |
| |
| bool | isConstraintValid () const |
| |
| virtual bool | isInput (const agxPowerLine::PhysicalDimension *dimension) const |
| | Determine if the given dimension is part of any of the input connections of this Connector.
|
| |
| virtual bool | isOutput (Connection *connection) const |
| | Find out if a connection is output from this connector.
|
| |
| virtual bool | isOutput (const agxPowerLine::PhysicalDimension *dimension) const |
| | Find out if the given dimension is part of any of the output connections.
|
| |
| virtual bool | postRestore (agxStream::StorageStream &str) |
| |
| virtual bool | postStore (agxStream::StorageStream &str) const |
| | Set values of constraints.
|
| |
| virtual bool | removeNotification (agxUtil::ConstraintHolder *holder, agxSDK::Simulation *simulation) override |
| | remove connector and constraint from simulation
|
| |
| virtual void | restore (agxStream::InputArchive &in) override |
| |
| virtual bool | restore (agxStream::StorageStream &str) override |
| | Restores internal data from stream.
|
| |
| void | setConstraint (agxPowerLine::PhysicalDimensionMultiBodyConstraintImplementation *constraint) |
| | set the constraint that represents this connector in the solver.
|
| |
| void | setDamping (agx::Real damping) |
| | Set the damping of the constraint.
|
| |
| void | setIgnoreForStoreRestoreStream (bool ignore) |
| |
| void | setNumPossibleInputConnections (int num) |
| | Define number of input dimensions the constraint should handle.
|
| |
| void | setNumPossibleOutputConnections (int num) |
| | Define number of output dimensions the constraint should handle.
|
| |
| void | setPowerLine (agxPowerLine::PowerLine *powerLine) |
| |
| virtual void | store (agxStream::OutputArchive &out) const override |
| |
| virtual bool | store (agxStream::StorageStream &str) const override |
| | Stores internal data for this segment into stream.
|
| |
| virtual bool | vetoConnect (agxPowerLine::Unit *unit) const |
| |
| | SubGraph () |
| |
| virtual bool | addNotification (agxSDK::Simulation *simulation)=0 |
| |
| | AGXSTREAM_DECLARE_ABSTRACT_SERIALIZABLE (agxPowerLine::SubGraph) |
| |
| virtual void | getConnectorsRecursive (ConnectorPtrVector &connectors) |
| | Fill the given vector with the Connectors that are held by this SubGraph.
|
| |
| Connector * | getEnclosingConnector () |
| |
| const Connector * | getEnclosingConnector () const |
| |
| SubGraph * | getEnclosingGraph () |
| |
| const SubGraph * | getEnclosingGraph () const |
| |
| Unit * | getEnclosingUnit () |
| |
| const Unit * | getEnclosingUnit () const |
| |
| const agxPowerLine::ConnectorRefVector & | getInternalConnectors () const |
| |
| const agxPowerLine::UnitRefVector & | getInternalUnits () const |
| |
| const agx::Name & | getName () const |
| |
| SubGraph * | getRootEnclosingGraph () |
| |
| const SubGraph * | getRootEnclosingGraph () const |
| |
| virtual void | getUnitsRecursive (UnitPtrVector &units) |
| | Fill the given vector with the Units that are held by this SubGraph.
|
| |
| bool | isEnclosedWithin (const SubGraph *component) const |
| |
| virtual bool | postUpdate (agx::Real timeStep) |
| |
| virtual void | prepareForRestore () |
| |
| virtual void | prepareForStore () |
| |
| virtual bool | preUpdate (agx::Real timeStep) |
| |
| virtual bool | removeNotification (agxUtil::ConstraintHolder *holder, agxSDK::Simulation *simulation)=0 |
| |
| virtual void | restore (agxStream::InputArchive &in) override |
| |
| virtual bool | restore (agxStream::StorageStream &str) |
| | Restores internal data from stream.
|
| |
| void | setName (const agx::Name &name) |
| | Set the name of this power line component.
|
| |
| void | spreadPowerLineToGraph () |
| |
| virtual void | store (agxStream::OutputArchive &out) const override |
| |
| virtual bool | store (agxStream::StorageStream &str) const |
| | Stores internal data into stream.
|
| |
| | Referenced () |
| | Default constructor.
|
| |
| | Referenced (const Referenced &) |
| |
| template<typename T > |
| T * | as () |
| | Subclass casting.
|
| |
| template<typename T > |
| const T * | as () const |
| |
| template<typename T > |
| T * | asSafe () |
| | Safe subclass casting, return nullptr if template type does not match.
|
| |
| template<typename T > |
| const T * | asSafe () const |
| |
| int | getReferenceCount () const |
| |
| template<typename T > |
| bool | is () const |
| | Subclass test.
|
| |
| Referenced & | operator= (const Referenced &) |
| | Assignment operator. Will increment the number of references to the referenced object.
|
| |
| void | reference (void *ptr=nullptr) const |
| | Explicitly increment the reference count by one, indicating that this object has another pointer which is referencing it.
|
| |
| void | unreference (void *ptr=nullptr) const |
| | Decrement the reference count by one, indicating that a pointer to this object is referencing it.
|
| |
| void | unreference_nodelete () const |
| | Decrement the reference count by one, indicating that a pointer to this object is referencing it.
|
| |
| virtual | ~Serializable () |
| | Destructor for normal C++ use but hidden from SWIG bindings.
|
| |
| virtual const char * | getClassName () const |
| |
| bool | getEnableSerialization () const |
| |
| bool | getEnableUuidGeneration () |
| |
| agx::UInt32 | getIndex () const |
| | This index is given at creation of this object.
|
| |
| virtual StorageAgent * | getStorageAgent () const =0 |
| |
| agx::Uuid | getUuid () const |
| |
| bool | isFinished () const |
| |
| void | setEnableSerialization (bool flag) |
| | Set to false to disable serialization of this object.
|
| |
| void | setFinished () |
| | Tells this class that it is restored correctly and should not be deleted during destruction of an Archive.
|
| |
| void | setUuid (const agx::Uuid &uuid) |
| | Explicitly set a Uuid on a serializable object.
|
| |
Single disk plate clutch with dry friction.
Input and output shafts are connected to plates with rough surfaces. A spring loaded mechanism increases the normal force between the plates between a minimum and maximum, giving rise to the concept of torque capacity. When the plates are at maximum distance from each other, no force is transmitted. When they are at zero distance, maximum pressure is applied.
Together with Coulomb friction, this keeps the plates rotating at nearly the same angular velocity untill the stick-slip transition is reached, alternately, when the torque required to move the output shaft at the same velocity as the input shaft reaches the torque capacity. This happens when the load on the output shaft is too difficult to move. If the two disks move relative to each other, this is called slipping so one can read the slip velocity at any time.
The "opening fraction" here represents the value of the torque capacity in proportion to the maximum capacity, i.e., when the plates are fully closed, i.e., maximum normal force is achieved. As for most clutches, this model includes a "locked" mode in which a clamp is activated to prevent any slip. This stays "ON" until the clutch is disengaged, or if the output shaft starts to move faster but in the same direction as the input shaft, as in the case of dynamic breaking.
This model has two modes, namely, manual and automatic. In the manual mode, the user is responsible to adjust the opening fraction, or set the lock mechanism directly. This can be done using a control algorithm and an event listener. For the automatic mode, a time constant determines how long it takes to go from fully open to fully engaged. The function "engage" determines whether we are ramping up or down. Setting auto lock mode activates logic to activate or deactivate the lock according to simple logic. If the slip velocity is small in proportion of the input shaft velocity, the lock is activated. If either "engage(false)" function is called or the torque between the places is negative – dynamic braking – then the lock is deactivated.
The maximum available torque before slipping for a given opening fraction \(f\) is ‘ \(fT_c\)’ where \(T_c\) is the torque capacity defined by
\[
T_c = 2\frac{2}{3}\mu\frac{r_2^3-r_1^3}{r_2^2-r_1^2}F
\]
where \(r_i\) are the outer and inner radii. This defaults to a ‘reasonable’ number corresponding to a passenger car, namely, around 40 Nm
Automatic engagement makes the fraction increase linearly from the time the "engage(true)" function is called, or decreases linearly from the time the "engage(false)" is called.
We assume that the pressure plate is a linear spring so that $F$ is directly proportional to it's position.
Definition at line 80 of file DryClutch.h.

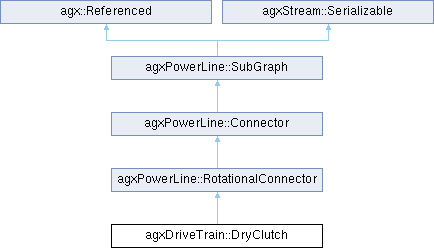
 Inheritance diagram for agxDriveTrain::DryClutch:
 1.9.6