|
| | Beam (BeamModel *model, agx::UInt resolution, agx::Real length) |
| | Construct a beam given model, resolution (number of elements) and total length.
|
| |
| agx::LockJointRef | attach (BeamSegment *segment, agx::Bool atSegmentBegin, agx::RigidBody *otherRb=nullptr, agx::Bool adoptModelProperties=false) const |
| | Utility method to attach a given segment (of this beam) at begin or end (of the segment) to another rigid body and optionally adopt the material properties of the model of this beam.
|
| |
| agx::LockJointRef | attach (BeamSegment *segment, agx::Vec3 localSegmentPosition, agx::RigidBody *otherRb=nullptr, agx::Bool adoptModelProperties=false) const |
| | Utility method to attach a given segment (of this beam) at a local segment position to another rigid body and optionally adopt the material properties of the model of this beam.
|
| |
| agx::LockJointRef | attachBegin (agx::RigidBody *otherRb=nullptr, agx::Bool adoptModelProperties=false) const |
| | Utility method to attach the first segment of this beam at begin (of the segment) to another rigid body and optionally adopt the material properties of the model of this beam.
|
| |
| agx::LockJointRef | attachEnd (agx::RigidBody *otherRb=nullptr, agx::Bool adoptModelProperties=false) const |
| | Utility method to attach the last segment of this beam at end (of the segment) to another rigid body and optionally adopt the material properties of the model of this beam.
|
| |
| BeamStiffnessDamping | calculateSegmentStiffnessDamping () const |
| | Calculates per segment stiffness dependent on beam model moment of inertia, cross section area, beam segment length and number of segments in this beam.
|
| |
| BeamSegment * | findSegment (const agx::Vec3 &worldPoint) const |
| | Find the segment closest to the given world point.
|
| |
| agx::Vec3 | getBeginPosition () const |
| | Current begin position, in world coordinate frame, of this (initialized) beam.
|
| |
| BeamSegmentRange | getConstrainedSegments () const |
| |
| agx::Vec3 | getEndPosition () const |
| | Current end position, in world coordinate frame, of this (initialized) beam.
|
| |
| BeamModel * | getModel () const |
| |
| agx::UInt | getNumSegments () const |
| |
| virtual agx::Real | getRestLength () const override |
| |
| BeamSegment * | getSegment (agx::Real restLengthFromStart) const |
| | Finds the segment overlapping the given rest length from start.
|
| |
| BeamSegmentRange | getSegments () const |
| |
| agx::Bool | initialize () |
| | Initialize this beam, creating segments, constraints and assigning properties related to the model of this beam.
|
| |
| agx::Bool | isInitialized () const |
| |
| void | updateProperties () |
| | Propagate model specific properties, such as stiffness in the constraints.
|
| |
| virtual agx::Bool | addComponent (agxSDK::LinkedStructureComponent *component) |
| | Add new component to this linked structure.
|
| |
| virtual void | addGroup (agx::UInt32 id) |
| | Add group id to all segments in this linked structure.
|
| |
| virtual void | addGroup (const agx::Name &name) |
| | Add group name to all segments in this linked structure.
|
| |
| virtual void | addNotification (agxSDK::Simulation *) |
| | Called when this assembly is added to a simulation (given that it not already is in the simulation).
|
| |
| void | addNotification (agxSDK::Simulation *simulation) final override |
| | Called when this linked structure is added to the simulation.
|
| |
| virtual void | addNotification (Assembly *) |
| | Called when this assembly is added to another assembly.
|
| |
| | AGXSTREAM_DECLARE_SERIALIZABLE_BASE (agxSDK::LinkedStructure) |
| |
| virtual agx::Real | findCurrentLength (agx::Real restLengthFromStart) const |
| | Calculates the current length of a given rest length.
|
| |
| virtual agxCollide::GroupIdCollection | findGroupIdCollection () const |
| |
| virtual agx::Vec3 | findPoint (agx::Real restLengthFromStart) const |
| | Finds center point on this structure given rest length from the start.
|
| |
| virtual agx::Vec3 | findPoint (const agx::Vec3 &worldPoint) const |
| | Given any world point, find a center point on this structure that is closest to the given worldPoint.
|
| |
| virtual agx::Real | findRestLength (agx::Real currentLengthFromStart) const |
| | Calculates the rest length of a given current length from start.
|
| |
| virtual agx::Real | findRestLengthTo (const agx::Vec3 &worldPoint) const |
| | Given any world point, find a center point on this structure that is closest to the given worldPoint and return the rest length from start.
|
| |
| virtual agx::Real | findRestLengthTo (const agxSDK::LinkedSegment *segment) const |
| | Finds rest length to the start of the given segment.
|
| |
| virtual agx::Vec3 | getAngularVelocityDamping () const |
| |
| template<typename T > |
| T * | getComponent () const |
| |
| agxSDK::LinkedStructureComponent * | getComponent (const agx::Name &name) const |
| |
| virtual agx::Real | getCurrentLength () const |
| | Calculates and returns the total length of this linked structure, at current state.
|
| |
| virtual agx::UInt32 | getDisabledCollisionGroupId () const |
| |
| virtual agx::Bool | getEnableCollisions (const agx::RigidBody *rb) const |
| |
| virtual agx::Bool | getEnableCollisions (const agxCollide::Geometry *geometry) const |
| |
| virtual agx::Vec3 | getLinearVelocityDamping () const |
| |
| virtual agx::Real | getMass () const |
| | Calculates and returns the total mass of this linked structure.
|
| |
| virtual agx::Material * | getMaterial () const |
| |
| virtual agx::Real | getRestLength () const |
| | Calculates and returns the total length of this linked structure, at rest.
|
| |
| virtual agx::Real | getRestVolume () const |
| | Calculates and returns the total volume of this linked structure, at rest.
|
| |
| template<> |
| LinkedSegment * | getSegment (const agx::RigidBody *rb) const |
| |
| agx::UInt | getSegmentIndex (const agx::RigidBody *rb) const |
| |
| const agxSDK::LinkedSegmentContainer & | getSegmentsContainer () const |
| |
| virtual agx::UInt32 | getUniqueId () const |
| |
| virtual agx::Bool | hasGroup (agx::UInt32 id) const |
| |
| virtual agx::Bool | hasGroup (const agx::Name &name) const |
| |
| virtual agx::Bool | rebind () |
| | Make the current relative positions of all nodes the rest state.
|
| |
| virtual agx::Bool | removeComponent (agxSDK::LinkedStructureComponent *component) |
| | Remove an added component from this linked structure.
|
| |
| virtual void | removeGroup (agx::UInt32 id) |
| | Remove group id from all segments in this linked structure.
|
| |
| virtual void | removeGroup (const agx::Name &name) |
| | Remove group name from all segments in this linked structure.
|
| |
| virtual void | removeNotification (agxSDK::Simulation *) |
| | Called when this assembly is removed from a simulation.
|
| |
| void | removeNotification (agxSDK::Simulation *simulation) final override |
| | Called when this linked structure is added to the simulation.
|
| |
| virtual void | removeNotification (Assembly *) |
| | Called when this assembly is removed from another assembly.
|
| |
| agxSDK::LinkedSegmentRange< agxSDK::LinkedSegment > | segments () |
| |
| virtual void | setAngularVelocityDamping (const agx::Vec3 &angularVelocityDamping) |
| | Assigns angular velocity damping to all segments in this linked structure.
|
| |
| virtual void | setDisabledCollisionsId (const agx::Uuid &uuid) |
| | Set the collision id of this linked structure.
|
| |
| virtual void | setEnableCollisions (agx::RigidBody *rb, agx::Bool enable) |
| | Enable/disable collisions between the rigid body and all segments of this linked structure.
|
| |
| virtual void | setEnableCollisions (agxCollide::Geometry *geometry, agx::Bool enable) |
| | Enable/disable collisions between the geometry and all segments of this linked structure.
|
| |
| virtual void | setLinearVelocityDamping (const agx::Vec3 &linearVelocityDamping) |
| | Assigns linear velocity damping to all segments in this linked structure.
|
| |
| virtual void | setMaterial (agx::Material *material) |
| | Assign material to all segments in this linked structure.
|
| |
| virtual void | setUniqueId (const agx::Uuid &uuid) |
| | Set the unique id of this linked structure.
|
| |
| | Assembly () |
| | Default constructor.
|
| |
| bool | add (agx::Constraint *constraint) |
| | Add a constraint to the assembly.
|
| |
| bool | add (agx::ContactMaterial *contactMaterial) |
| | Add a contact material to this assembly.
|
| |
| bool | add (agx::Emitter *emitter) |
| | Add an emitter to this assembly.
|
| |
| bool | add (agx::Interaction *interaction) |
| | Add an interaction to this assembly.
|
| |
| bool | add (agx::MergedBody *mergedBody) |
| | Add a MergedBody to this assembly.
|
| |
| bool | add (agx::ObserverFrame *observerFrame) |
| | Add an ObserverFrame to this assembly.
|
| |
| bool | add (agx::RigidBody *body) |
| | Add a rigid body to the assembly.
|
| |
| bool | add (agxCollide::Geometry *geometry) |
| | Add a geometry to the assembly.
|
| |
| bool | add (agxSDK::EventListener *listener) |
| | Add a listener to the assembly.
|
| |
| bool | add (agxSDK::TerrainInstance *terrainInstance) |
| | Add a TerrainInstance to this assembly.
|
| |
| bool | add (agxSDK::TerrainToolInstance *toolInstance) |
| | Add a TerrainToolInstance to this assembly.
|
| |
| bool | add (agxStream::Serializable *object) |
| | Add an object of type serialized.
|
| |
| bool | add (Assembly *assembly) |
| | Add another assembly as child to this assembly.
|
| |
| virtual void | addNotification (agxSDK::Simulation *) |
| | Called when this assembly is added to a simulation (given that it not already is in the simulation).
|
| |
| virtual void | addNotification (Assembly *) |
| | Called when this assembly is added to another assembly.
|
| |
| | AGXSTREAM_DECLARE_SERIALIZABLE_BASE (agxSDK::Assembly) |
| |
| size_t | collect (agx::ConstraintRefVector &result, bool recursive=true) |
| |
| size_t | collect (agx::EmitterRefVector &result, bool recursive=true) |
| |
| size_t | collect (agx::InteractionRefVector &result, bool recursive=true) |
| |
| size_t | collect (agx::MergedBodyRefVector &result, bool recursive=true) |
| |
| size_t | collect (agx::ObserverFrameRefVector &result, bool recursive=true) |
| |
| size_t | collect (agx::ParticleSystemRefVector &result, bool recursive=true) |
| |
| size_t | collect (agx::RigidBodyRefVector &result, bool recursive=true) |
| |
| size_t | collect (agxCollide::GeometryRefVector &result, bool recursive=true) |
| |
| size_t | collect (agxSDK::AssemblyRefVector &result, bool recursive=true) |
| |
| size_t | collect (agxSDK::EventListenerRefVector &result, bool recursive=true) |
| |
| size_t | collect (agxSDK::TerrainInstanceRefVector &result, bool recursive=true) |
| |
| size_t | collect (agxSDK::TerrainToolInstanceRefVector &result, bool recursive=true) |
| |
| bool | empty () const |
| |
| const AssemblyRefSetVector & | getAssemblies () const |
| |
| agxSDK::Assembly * | getAssembly (const agx::Name &name, bool recursive=true) |
| | Find (linear search) and return named Assembly.
|
| |
| const agxSDK::Assembly * | getAssembly (const agx::Name &name, bool recursive=true) const |
| | Find (linear search) and return named Assembly.
|
| |
| agxSDK::Assembly * | getAssembly (const agx::Uuid &uuid, bool recursive=true) |
| | Find (linear search) and return an Assembly matching the given uuid.
|
| |
| const agxSDK::Assembly * | getAssembly (const agx::Uuid &uuid, bool recursive=true) const |
| | Find (linear search) and return an Assembly matching the given uuid.
|
| |
| agx::Constraint * | getConstraint (const agx::Name &name, bool recursive=true) |
| | Find (linear search) and return named Constraint.
|
| |
| template<typename T > |
| T * | getConstraint (const agx::Name &name, bool recursive=true) |
| | Find and return named Constraint of a template type, for example Hinge:
|
| |
| const agx::Constraint * | getConstraint (const agx::Name &name, bool recursive=true) const |
| | Find (linear search) and return named Constraint.
|
| |
| template<typename T > |
| const T * | getConstraint (const agx::Name &name, bool recursive=true) const |
| | Find and return named Constraint of a template type, for example Hinge:
|
| |
| agx::Constraint * | getConstraint (const agx::Uuid &uuid, bool recursive=true) |
| | Find and return a pointer to a Constraint with the given uuid.
|
| |
| const agx::Constraint * | getConstraint (const agx::Uuid &uuid, bool recursive=true) const |
| | Find (linear search) and return a pointer to a Constraint with the given uuid.
|
| |
| agx::Constraint1DOF * | getConstraint1DOF (const agx::Name &name, bool recursive=true) |
| |
| agx::Constraint2DOF * | getConstraint2DOF (const agx::Name &name, bool recursive=true) |
| |
| const agx::ConstraintRefSetVector & | getConstraints () const |
| |
| const agx::EmitterRefSetVector & | getEmitters () const |
| |
| const EventListenerRefSetVector & | getEventListeners () const |
| |
| virtual agx::Frame * | getFrame () |
| | Return a reference to the frame containing transformation and velocity information for this assembly.
|
| |
| virtual const agx::Frame * | getFrame () const |
| |
| const agxCollide::GeometryRefSetVector & | getGeometries () const |
| |
| agxCollide::Geometry * | getGeometry (const agx::Name &name, bool recursive=true) |
| | Find (linear search) and return named collision Geometry.
|
| |
| const agxCollide::Geometry * | getGeometry (const agx::Name &name, bool recursive=true) const |
| | Find (linear search) and return named collision Geometry.
|
| |
| agxCollide::Geometry * | getGeometry (const agx::Uuid &uuid, bool recursive=true) |
| | Find (linear search) and return a Geometry matching the given uuid.
|
| |
| const agxCollide::Geometry * | getGeometry (const agx::Uuid &uuid, bool recursive=true) const |
| | Find (linear search) and return a Geometry matching the given uuid.
|
| |
| const agx::InteractionRefSetVector & | getInteractions () const |
| |
| agx::Vec3 | getLocalPosition () const |
| |
| agx::Quat | getLocalRotation () const |
| |
| const agx::AffineMatrix4x4 & | getLocalTransform () const |
| |
| const agx::MergedBodyRefSetVector & | getMergedBodies () const |
| |
| agx::MergedBody * | getMergedBody (const agx::Uuid &uuid, bool recursive=true) |
| | Find (linear search) and return an MergedBody matching the given uuid.
|
| |
| const agx::MergedBody * | getMergedBody (const agx::Uuid &uuid, bool recursive=true) const |
| | Find (linear search) and return an MergedBody matching the given uuid.
|
| |
| agx::Name | getName () const |
| |
| agx::ObserverFrame * | getObserverFrame (const agx::Name &name, bool recursive=true) |
| | Find (linear search) and return an ObserverFrame matching the given uuid.
|
| |
| const agx::ObserverFrame * | getObserverFrame (const agx::Name &name, bool recursive=true) const |
| | Find (linear search) and return an ObserverFrame matching the given uuid.
|
| |
| agx::ObserverFrame * | getObserverFrame (const agx::Uuid &uuid, bool recursive=true) |
| | Find (linear search) and return an ObserverFrame matching the given uuid.
|
| |
| const agx::ObserverFrame * | getObserverFrame (const agx::Uuid &uuid, bool recursive=true) const |
| | Find (linear search) and return an ObserverFrame matching the given uuid.
|
| |
| const agx::ObserverFrameRefSetVector & | getObserverFrames () const |
| |
| Assembly * | getParent () |
| |
| const Assembly * | getParent () const |
| |
| agx::Frame * | getParentFrame () |
| |
| const agx::Frame * | getParentFrame () const |
| |
| const agx::ParticleSystemRefSetVector & | getParticleSystems () const |
| |
| const agx::RigidBodyRefSetVector & | getRigidBodies () const |
| |
| agx::RigidBody * | getRigidBody (const agx::Name &name, bool recursive=true) |
| | Find (linear search) and return named RigidBody.
|
| |
| const agx::RigidBody * | getRigidBody (const agx::Name &name, bool recursive=true) const |
| | Find (linear search) and return named RigidBody.
|
| |
| agx::RigidBody * | getRigidBody (const agx::Uuid &uuid, bool recursive=true) |
| | Find (linear search) and return a pointer to a RigidBody with the given uuid.
|
| |
| const agx::RigidBody * | getRigidBody (const agx::Uuid &uuid, bool recursive=true) const |
| | Find (linear search) and return a pointer to a RigidBody with the given uuid.
|
| |
| agxSDK::Simulation * | getSimulation () |
| |
| const agxSDK::Simulation * | getSimulation () const |
| |
| agxSDK::TerrainInstance * | getTerrainInstance (const agx::Uuid &uuid, bool recursive=true) |
| | Find (linear search) and return an TerrainInstance matching the given uuid.
|
| |
| const agxSDK::TerrainInstance * | getTerrainInstance (const agx::Uuid &uuid, bool recursive=true) const |
| | Find (linear search) and return an TerrainInstance matching the given uuid.
|
| |
| const agxSDK::TerrainInstanceRefSetVector & | getTerrainInstances () const |
| |
| agxSDK::TerrainToolInstance * | getTerrainToolInstance (const agx::Uuid &uuid, bool recursive=true) |
| | Find (linear search) and return an TerrainToolInstance matching the given uuid.
|
| |
| const agxSDK::TerrainToolInstance * | getTerrainToolInstance (const agx::Uuid &uuid, bool recursive=true) const |
| | Find (linear search) and return an TerrainToolInstance matching the given uuid.
|
| |
| const agxSDK::TerrainToolInstanceRefSetVector & | getTerrainToolInstances () const |
| |
| Type | getType () const |
| |
| bool | remove (agx::Constraint *constraint) |
| | Remove a constraint from this assembly (does not recurse down in tree).
|
| |
| bool | remove (agx::ContactMaterial *contactMaterial) |
| | Remove a contact material from this assembly.
|
| |
| bool | remove (agx::Emitter *emitter) |
| | Remove an emitter from this assembly.
|
| |
| bool | remove (agx::Interaction *interaction) |
| | Remove an interaction from this assembly.
|
| |
| bool | remove (agx::MergedBody *mergedBody) |
| | Remove a MergedBody from this assembly.
|
| |
| bool | remove (agx::ObserverFrame *observerFrame, bool resetParentFrame=true) |
| | Remove an ObserverFrame from this assembly.
|
| |
| bool | remove (agx::RigidBody *body, bool removeAssociatedGeometries=false, bool resetParentFrame=true) |
| | Remove a rigid body from this assembly (does not recurse down in tree).
|
| |
| bool | remove (agxCollide::Geometry *geometry, bool resetParentFrame=true) |
| | Remove a geometry from this assembly (does not recurse down in tree).
|
| |
| bool | remove (agxSDK::TerrainInstance *terrainInstance) |
| | Remove a TerrainInstance from this assembly.
|
| |
| bool | remove (agxSDK::TerrainToolInstance *toolInstance) |
| | Remove a TerrainToolInstance from this assembly.
|
| |
| bool | remove (Assembly *assembly, bool resetParentFrame=true) |
| | Remove a child assembly from a parent.
|
| |
| bool | remove (EventListener *listener) |
| | Remove an EventListener from the assembly.
|
| |
| virtual void | removeNotification (agxSDK::Simulation *) |
| | Called when this assembly is removed from a simulation.
|
| |
| virtual void | removeNotification (Assembly *) |
| | Called when this assembly is removed from another assembly.
|
| |
| bool | reset (bool resetParentFrame=true) |
| | If this assembly is not added to a simulation it will clear all added bodies etc.
|
| |
| virtual void | setAngularVelocity (const agx::Vec3 &velocity) |
| | Set the angular velocity (in world frame) recursively for all rigid bodies stored in assembly.
|
| |
| void | setLocalPosition (agx::Real x, agx::Real y, agx::Real z) |
| | Set the position of the assembly relative to its frame's parent frame.
|
| |
| void | setLocalPosition (const agx::Vec3 &p) |
| | Set the position of the assembly relative to its frame's parent frame.
|
| |
| void | setLocalRotation (const agx::EulerAngles &e) |
| | Set the rotation of the assembly relative to its frame's parent frame.
|
| |
| void | setLocalRotation (const agx::Quat &q) |
| | Set the rotation of the assembly relative to its frame's parent frame.
|
| |
| void | setLocalTransform (const agx::AffineMatrix4x4 &matrix) |
| | Assign the local transformation matrix for this assembly, ignoring any eventual parent transformation.
|
| |
| void | setName (const agx::Name &name) |
| | Set the name of this Assembly.
|
| |
| bool | setParentFrame (agx::Frame *frame) |
| | Set the parent frame of this assembly's frame.
|
| |
| void | setPosition (agx::Real x, agx::Real y, agx::Real z) |
| | Set the position of the frame in world coordinates.
|
| |
| void | setPosition (const agx::Vec3 &p) |
| | Set the position of the frame in world coordinates.
|
| |
| void | setRotation (const agx::EulerAngles &e) |
| | Set the rotation of the assembly relative to world frame.
|
| |
| void | setRotation (const agx::OrthoMatrix3x3 &m) |
| | Set the rotation of the assembly relative to world frame.
|
| |
| void | setRotation (const agx::Quat &q) |
| | Set the rotation of the assembly relative to world frame.
|
| |
| void | setTransform (const agx::AffineMatrix4x4 &matrix) |
| | Set the transform of the assembly.
|
| |
| virtual void | setVelocity (const agx::Vec3 &velocity) |
| | Set the linear velocity (in world frame) recursively for all rigid bodies stored in assembly.
|
| |
| bool | transfer (agxSDK::Assembly *target) |
| | Transfer all the content from this assembly to the target, including name and transformation.
|
| |
| virtual void | traverse (AssemblyVisitor *visitor) |
| | Traverse the assembly tree recursively using a visitor.
|
| |
| virtual void | traverse (const AssemblyVisitor *visitor) const |
| |
| | Referenced () |
| | Default constructor.
|
| |
| | Referenced (const Referenced &) |
| |
| template<typename T > |
| T * | as () |
| | Subclass casting.
|
| |
| template<typename T > |
| const T * | as () const |
| |
| template<typename T > |
| T * | asSafe () |
| | Safe subclass casting, return nullptr if template type does not match.
|
| |
| template<typename T > |
| const T * | asSafe () const |
| |
| int | getReferenceCount () const |
| |
| template<typename T > |
| bool | is () const |
| | Subclass test.
|
| |
| Referenced & | operator= (const Referenced &) |
| | Assignment operator. Will increment the number of references to the referenced object.
|
| |
| void | reference (void *ptr=nullptr) const |
| | Explicitly increment the reference count by one, indicating that this object has another pointer which is referencing it.
|
| |
| void | unreference (void *ptr=nullptr) const |
| | Decrement the reference count by one, indicating that a pointer to this object is referencing it.
|
| |
| void | unreference_nodelete () const |
| | Decrement the reference count by one, indicating that a pointer to this object is referencing it.
|
| |
| virtual | ~Serializable () |
| | Destructor for normal C++ use but hidden from SWIG bindings.
|
| |
| virtual const char * | getClassName () const |
| |
| bool | getEnableSerialization () const |
| |
| bool | getEnableUuidGeneration () |
| |
| agx::UInt32 | getIndex () const |
| | This index is given at creation of this object.
|
| |
| virtual StorageAgent * | getStorageAgent () const =0 |
| |
| agx::Uuid | getUuid () const |
| |
| bool | isFinished () const |
| |
| void | setEnableSerialization (bool flag) |
| | Set to false to disable serialization of this object.
|
| |
| void | setFinished () |
| | Tells this class that it is restored correctly and should not be deleted during destruction of an Archive.
|
| |
| void | setUuid (const agx::Uuid &uuid) |
| | Explicitly set a Uuid on a serializable object.
|
| |

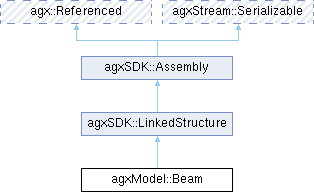
 Inheritance diagram for agxModel::Beam:
 1.9.6