|
| | Lidar (agx::Frame *frame, LidarModel *model) |
| | Construct this lidar given frame and model.
|
| |
| virtual agx::Frame * | getFrame () const override |
| |
| LidarFrameNode * | getFrameNode () const |
| |
| LidarModel * | getModel () const |
| |
| RtOutputHandler * | getOutputHandler () const |
| |
| virtual ISensorOutputHandler * | getOutputHandlerBase () const override |
| |
| LidarRayDistortionHandler * | getRayDistortionHandler () const |
| |
| virtual void | setFrame (agx::Frame *frame) override |
| | Assign new frame to this lidar.
|
| |
| | FrameAttachedSensor ()=default |
| | Default constructor.
|
| |
| virtual agx::Frame * | getFrame () const =0 |
| |
| virtual void | setFrame (agx::Frame *frame)=0 |
| | Assign a new parent frame to attach this sensor to.
|
| |
| | Sensor ()=default |
| | Default constructor.
|
| |
| ISensorOutputHandler * | getOutputHandler () const |
| |
| virtual ISensorOutputHandler * | getOutputHandlerBase () const =0 |
| |
| | SystemNode (const SystemNode &)=delete |
| | Disallow direct copying of nodes.
|
| |
| virtual | ~SystemNode ()=default |
| |
| bool | addChild (SystemNode *child) |
| | Add unique child to this node.
|
| |
| virtual bool | addNotification () |
| | Called when this system node has been added to a sensor environment.
|
| |
| bool | appendChild (SystemNode *child) |
| | Append child to vector of children, silently.
|
| |
| virtual void | cleanup ()=0 |
| | The sensor environment is being put down, clean everything.
|
| |
| virtual void | complete () |
| | Complete the execution of this system, finishing the integration forward in time.
|
| |
| bool | detachChild (SystemNode *child) |
| | Detach/erase child from vector of children, silently.
|
| |
| virtual bool | eraseAndConnect () |
| | Erase this node from the tree and connect its children to the current parent of this node.
|
| |
| virtual void | execute (const CallbackData &data) |
| | Execute this system, integrating it data.dt forward in time.
|
| |
| template<typename T > |
| T * | findChild (bool recurse=true) const |
| | Find child of given type.
|
| |
| template<typename PredicateT > |
| SystemNode * | findChild (PredicateT pred, bool recurse=true) const |
| | Find child given predicate pred.
|
| |
| template<typename T > |
| T * | findParent () const |
| |
| template<typename PredicateT > |
| SystemNode * | findParent (PredicateT pred) const |
| | Find parent given predicate.
|
| |
| template<typename T > |
| T * | getChild () const |
| | Searches children for a node of given type.
|
| |
| SystemNode * | getChild (size_t index) const |
| |
| bool | getEnable () const |
| |
| Environment * | getEnvironment () const |
| |
| const agx::Name & | getName () const |
| |
| size_t | getNumChildren () const |
| |
| SystemNode * | getParent () const |
| |
| SystemNode * | getRoot () const |
| |
| bool | hasChild (const SystemNode *child, bool recurse=true) const |
| |
| virtual bool | insertParent (SystemNode &parent) |
| | Inserts new parent to this node.
|
| |
| virtual bool | onAdd (agx::Referenced &instance) |
| | Called when an object has been added to the sensor environment.
|
| |
| virtual void | onChildAdded (SystemNode &child) |
| | Called when child has been added to this parent.
|
| |
| virtual void | onChildRemoved (SystemNode &child) |
| | Called when child has been removed from this parent.
|
| |
| virtual bool | onRemove (agx::Referenced &instance) |
| | Called when an object has been removed from the sensor environment.
|
| |
| bool | removeChild (SystemNode *child) |
| | Remove child from this node.
|
| |
| virtual void | removeNotification () |
| | Called when this system node is being removed from a sensor environment.
|
| |
| virtual void | result (const CallbackData &data) |
| | If necessary assemble, and fetch results related to this system node after a step by data.dt has been completed.
|
| |
| void | setEnable (bool enable) |
| | Enable/disable this node.
|
| |
| void | setName (const agx::Name &name) |
| | Assign name to this node.
|
| |
| virtual void | synchronize (const CallbackData &data) |
| | Synchronization from the main thread.
|
| |
| virtual void | synchronizeGraphics (const agxRender::RenderManager &renderManager) |
| | At the very end of a step, synchronize any graphics related aspects of the system node.
|
| |
| template<typename VisitorT > |
| SystemNode * | visitBf (VisitorT visitor) const |
| | Visit the tree from, including, this node until callback returns true - using breadth first traversal.
|
| |
| template<typename VisitorT > |
| void | visitChildren (VisitorT visitor, bool recurse=true) const |
| | Visit all children with func as void( const SystemNode& child ).
|
| |
| template<typename VisitorT > |
| SystemNode * | visitChildrenBf (VisitorT visitor) const |
| | Visit the tree from the children of this node until callback returns true - using breadth first traversal.
|
| |
| template<typename VisitorT > |
| SystemNode * | visitChildrenDf (VisitorT visitor) const |
| | Visit the tree from the children of this node until callback returns true - using depth first traversal.
|
| |
| template<typename T , typename VisitorT > |
| void | visitChildrenOfType (VisitorT visitor, bool recurse=true) const |
| | Visit all children with func as void( const T& child ).
|
| |
| template<typename VisitorT > |
| SystemNode * | visitDf (VisitorT visitor) const |
| | Visit the tree from, including, this node until callback returns true - using depth first traversal.
|
| |
| | Referenced () |
| | Default constructor.
|
| |
| | Referenced (const Referenced &) |
| |
| template<typename T > |
| T * | as () |
| | Subclass casting.
|
| |
| template<typename T > |
| const T * | as () const |
| |
| template<typename T > |
| T * | asSafe () |
| | Safe subclass casting, return nullptr if template type does not match.
|
| |
| template<typename T > |
| const T * | asSafe () const |
| |
| int | getReferenceCount () const |
| |
| template<typename T > |
| bool | is () const |
| | Subclass test.
|
| |
| Referenced & | operator= (const Referenced &) |
| | Assignment operator. Will increment the number of references to the referenced object.
|
| |
| void | reference (void *ptr=nullptr) const |
| | Explicitly increment the reference count by one, indicating that this object has another pointer which is referencing it.
|
| |
| void | unreference (void *ptr=nullptr) const |
| | Decrement the reference count by one, indicating that a pointer to this object is referencing it.
|
| |
| void | unreference_nodelete () const |
| | Decrement the reference count by one, indicating that a pointer to this object is referencing it.
|
| |
| virtual | ~Serializable () |
| | Destructor for normal C++ use but hidden from SWIG bindings.
|
| |
| virtual const char * | getClassName () const |
| |
| bool | getEnableSerialization () const |
| |
| bool | getEnableUuidGeneration () |
| |
| agx::UInt32 | getIndex () const |
| | This index is given at creation of this object.
|
| |
| virtual StorageAgent * | getStorageAgent () const =0 |
| |
| agx::Uuid | getUuid () const |
| |
| bool | isFinished () const |
| |
| void | setEnableSerialization (bool flag) |
| | Set to false to disable serialization of this object.
|
| |
| void | setFinished () |
| | Tells this class that it is restored correctly and should not be deleted during destruction of an Archive.
|
| |
| void | setUuid (const agx::Uuid &uuid) |
| | Explicitly set a Uuid on a serializable object.
|
| |
Lidar instance class defined by a frame/transform and a model.
Any output, such as point cloud, intensity, normals etc., are given as seen from the lidar frame.
Definition at line 39 of file Lidar.h.

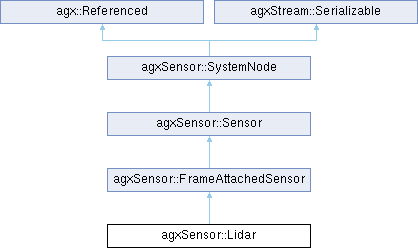
 Inheritance diagram for agxSensor::Lidar:
 1.9.6