|
AGX Dynamics 2.42.3.1
|
|
AGX Dynamics 2.42.3.1
|
Class for reading contact forces between granular bodies and rigid bodies and geometries. More...
#include <GranularContactForceReader.h>
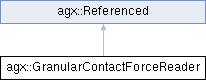
 Inheritance diagram for agx::GranularContactForceReader:
Public Member Functions | |
| GranularContactForceReader (const agxSDK::Simulation *sim) | |
| agx::Vec3 | getContactForces (const agx::RigidBody *rb) |
| Get all contact forces on a single rigid body. | |
| agx::Vec3 | getContactForces (const agxCollide::Geometry *geo) |
| Get all contact forces on a single geometry. | |
| agx::Vec3 | getFrictionContactForces (const agx::RigidBody *rb) |
| Get all tangential forces on a single rigid body. | |
| agx::Vec3 | getFrictionContactForces (const agxCollide::Geometry *geo) |
| Get all tangential forces on a single geometry. | |
| agx::Vec3 | getNormalContactForces (const agx::RigidBody *rb) |
| Get all normal forces on a single rigid body. | |
| agx::Vec3 | getNormalContactForces (const agxCollide::Geometry *geo) |
| Get all normal forces on a single geometry. | |
| agx::Vec3 | getSumAbsoluteContactForces (const agx::RigidBody *rb) |
| Get the sum of all contact forces on a single rigid body, summing the absolute forces per contact point. | |
| agx::Vec3 | getSumAbsoluteContactForces (const agxCollide::Geometry *geo) |
| Get the sum of all contact forces on a single geometry, summing the absolute forces per contact point. | |
| agx::Vec3 | getSumAbsoluteFrictionContactForces (const agx::RigidBody *rb) |
| Get the sum of all tangential forces on a single rigid body, summing the absolute forces per contact point. | |
| agx::Vec3 | getSumAbsoluteFrictionContactForces (const agxCollide::Geometry *geo) |
| Get the sum of all tangential forces on a single geometry, summing the absolute forces per contact point. | |
| agx::Vec3 | getSumAbsoluteNormalContactForces (const agx::RigidBody *rb) |
| Get the sum of all normal forces on a single rigid body, summing the absolute forces per contact point. | |
| agx::Vec3 | getSumAbsoluteNormalContactForces (const agxCollide::Geometry *geo) |
| Get the sum of all normal forces on a single geometry, summing the absolute forces per contact point. | |
| void | setSimulation (agxSDK::Simulation *sim) |
| Update reference to Simulation. | |
| Public Member Functions inherited from agx::Referenced | |
| Referenced () | |
| Default constructor. | |
| Referenced (const Referenced &) | |
| template<typename T > | |
| T * | as () |
| Subclass casting. | |
| template<typename T > | |
| const T * | as () const |
| template<typename T > | |
| T * | asSafe () |
| Safe subclass casting, return nullptr if template type does not match. | |
| template<typename T > | |
| const T * | asSafe () const |
| int | getReferenceCount () const |
| template<typename T > | |
| bool | is () const |
| Subclass test. | |
| Referenced & | operator= (const Referenced &) |
| Assignment operator. Will increment the number of references to the referenced object. | |
| void | reference (void *ptr=nullptr) const |
| Explicitly increment the reference count by one, indicating that this object has another pointer which is referencing it. | |
| void | unreference (void *ptr=nullptr) const |
| Decrement the reference count by one, indicating that a pointer to this object is referencing it. | |
| void | unreference_nodelete () const |
| Decrement the reference count by one, indicating that a pointer to this object is referencing it. | |
Additional Inherited Members | |
| Static Public Member Functions inherited from agx::Referenced | |
| template<typename T > | |
| static bool | ValidateCast (const Referenced *object) |
| Protected Member Functions inherited from agx::Referenced | |
| virtual | ~Referenced () |
| Destructor. | |
| void | allocateObserverVector () const |
| void | deleteUsingDeleteHandler () const |
| Static Protected Member Functions inherited from agx::Referenced | |
| static DeleteHandler * | getDeleteHandler () |
| static void | setDeleteHandler (DeleteHandler *handler) |
| Internal: Set a DeleteHandler to which deletion of all referenced counted objects will be delegated to. | |
| Protected Attributes inherited from agx::Referenced | |
| Mutex | m_mutex |
| ObserverContainer | m_observers |
| AtomicValue | m_refCount |
Class for reading contact forces between granular bodies and rigid bodies and geometries.
If this class is used several times per time step, it is usually faster to do this "by hand" (with a smart for-loop over the contacts from Space::getGeometryContacts()), since this class will loop over these contacts separately for each call.
Definition at line 33 of file GranularContactForceReader.h.
| agx::GranularContactForceReader::GranularContactForceReader | ( | const agxSDK::Simulation * | sim | ) |
| agx::Vec3 agx::GranularContactForceReader::getContactForces | ( | const agx::RigidBody * | rb | ) |
Get all contact forces on a single rigid body.
| agx::Vec3 agx::GranularContactForceReader::getContactForces | ( | const agxCollide::Geometry * | geo | ) |
Get all contact forces on a single geometry.
| agx::Vec3 agx::GranularContactForceReader::getFrictionContactForces | ( | const agx::RigidBody * | rb | ) |
Get all tangential forces on a single rigid body.
| agx::Vec3 agx::GranularContactForceReader::getFrictionContactForces | ( | const agxCollide::Geometry * | geo | ) |
Get all tangential forces on a single geometry.
| agx::Vec3 agx::GranularContactForceReader::getNormalContactForces | ( | const agx::RigidBody * | rb | ) |
Get all normal forces on a single rigid body.
| agx::Vec3 agx::GranularContactForceReader::getNormalContactForces | ( | const agxCollide::Geometry * | geo | ) |
Get all normal forces on a single geometry.
| agx::Vec3 agx::GranularContactForceReader::getSumAbsoluteContactForces | ( | const agx::RigidBody * | rb | ) |
Get the sum of all contact forces on a single rigid body, summing the absolute forces per contact point.
| agx::Vec3 agx::GranularContactForceReader::getSumAbsoluteContactForces | ( | const agxCollide::Geometry * | geo | ) |
Get the sum of all contact forces on a single geometry, summing the absolute forces per contact point.
| agx::Vec3 agx::GranularContactForceReader::getSumAbsoluteFrictionContactForces | ( | const agx::RigidBody * | rb | ) |
Get the sum of all tangential forces on a single rigid body, summing the absolute forces per contact point.
| agx::Vec3 agx::GranularContactForceReader::getSumAbsoluteFrictionContactForces | ( | const agxCollide::Geometry * | geo | ) |
Get the sum of all tangential forces on a single geometry, summing the absolute forces per contact point.
| agx::Vec3 agx::GranularContactForceReader::getSumAbsoluteNormalContactForces | ( | const agx::RigidBody * | rb | ) |
Get the sum of all normal forces on a single rigid body, summing the absolute forces per contact point.
| agx::Vec3 agx::GranularContactForceReader::getSumAbsoluteNormalContactForces | ( | const agxCollide::Geometry * | geo | ) |
Get the sum of all normal forces on a single geometry, summing the absolute forces per contact point.
| void agx::GranularContactForceReader::setSimulation | ( | agxSDK::Simulation * | sim | ) |
Update reference to Simulation.
 1.9.6